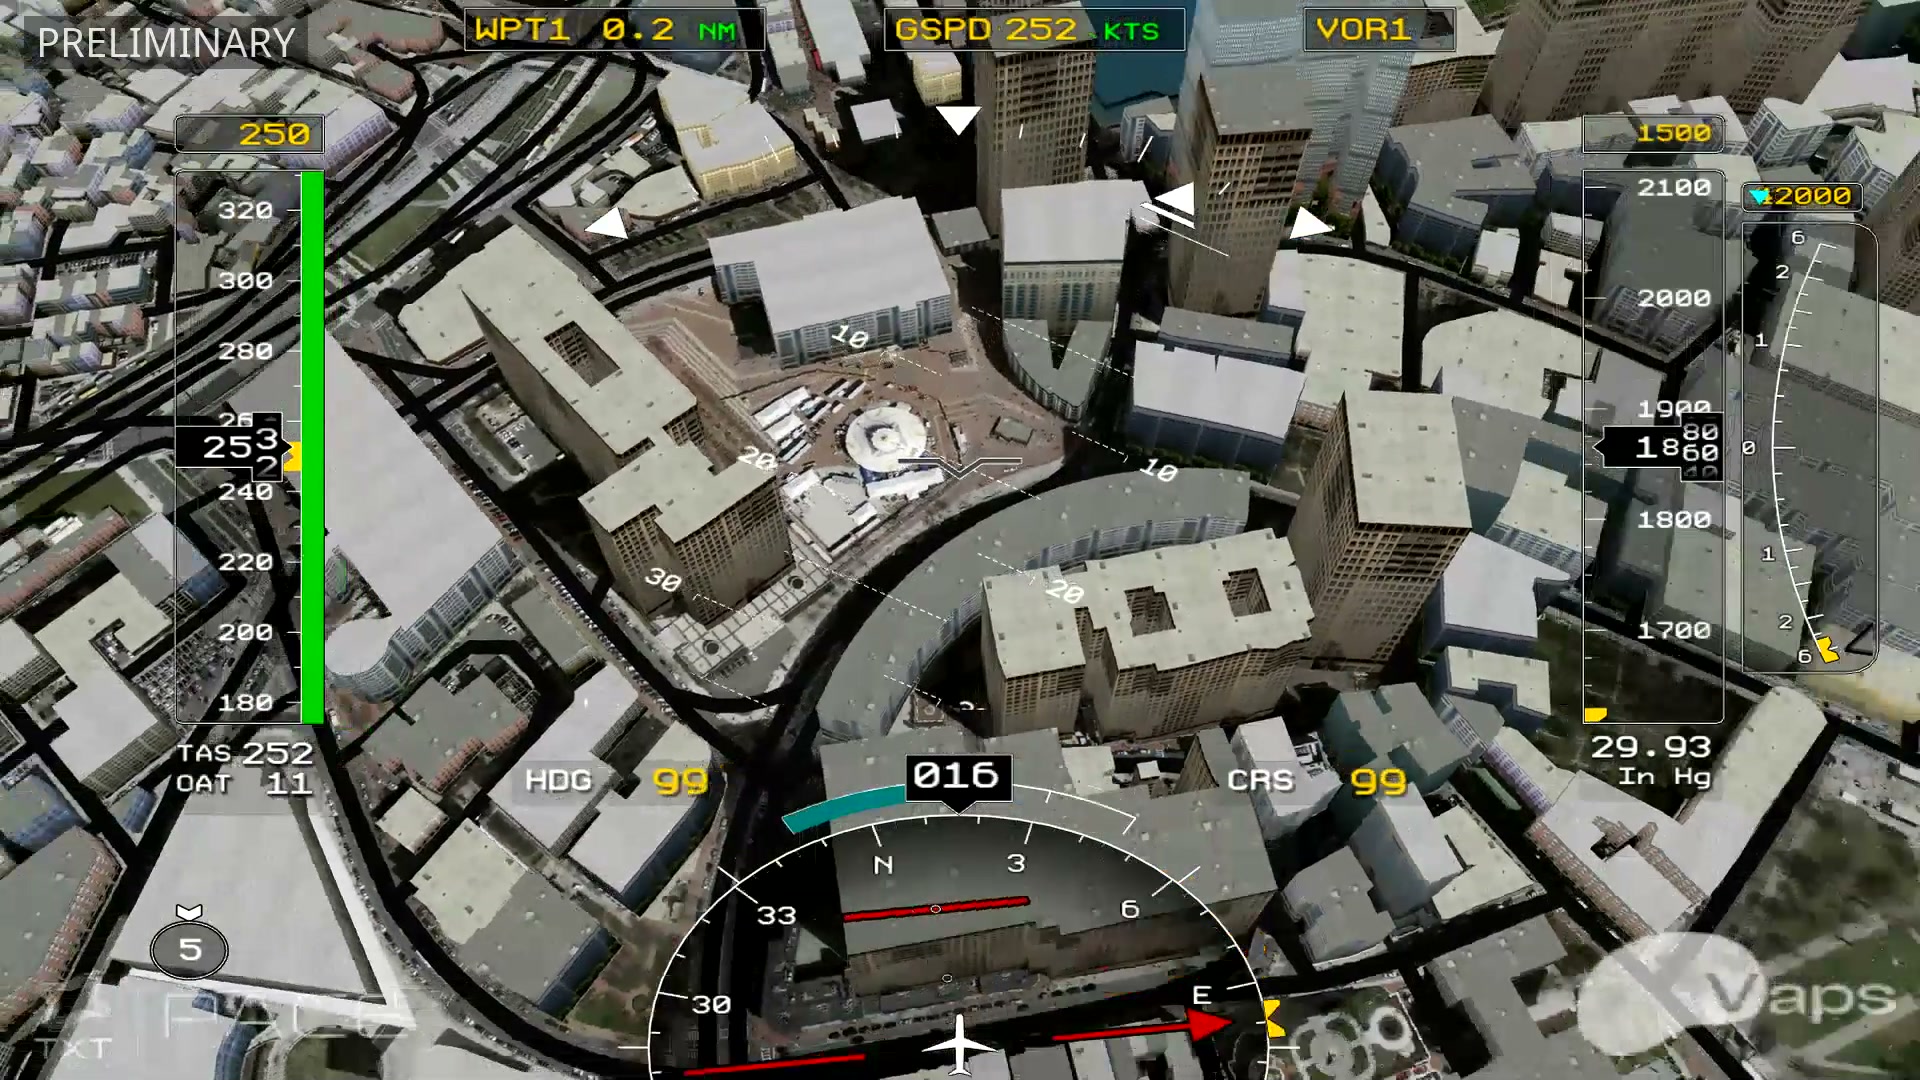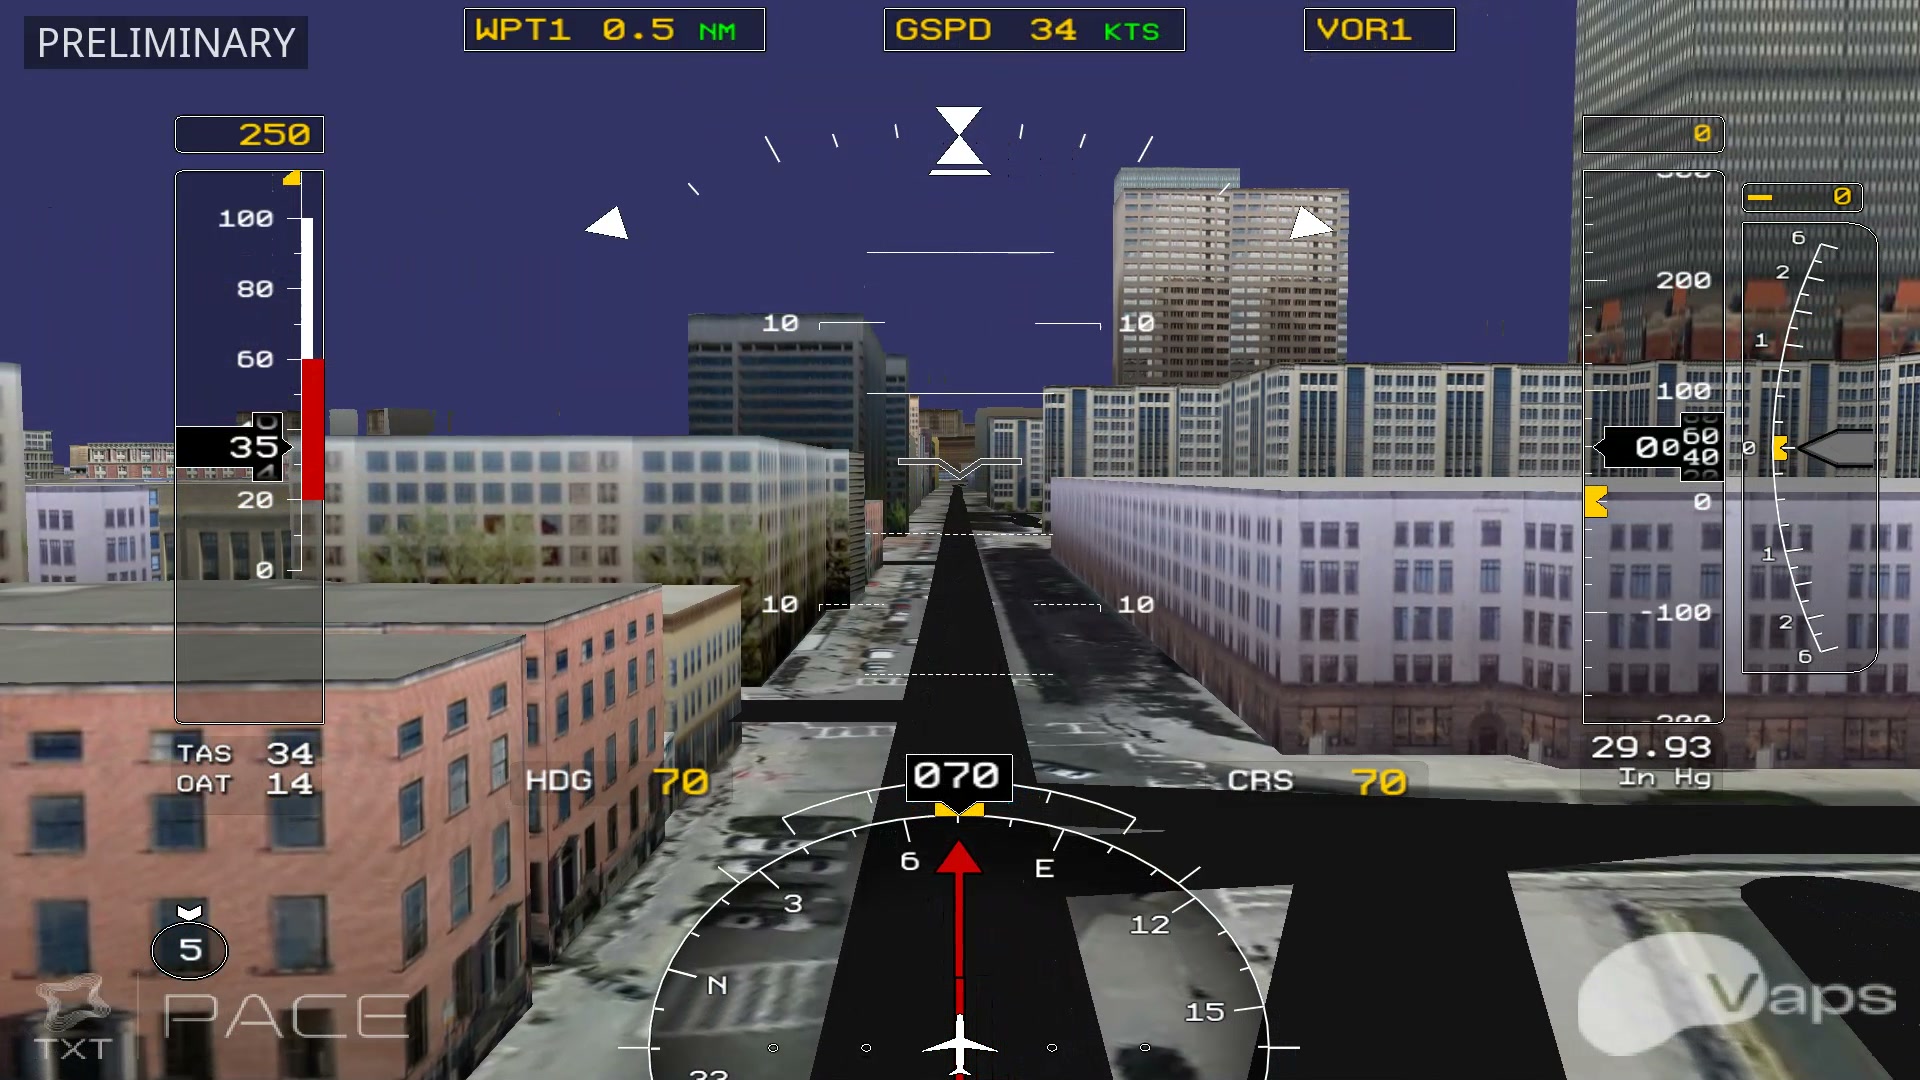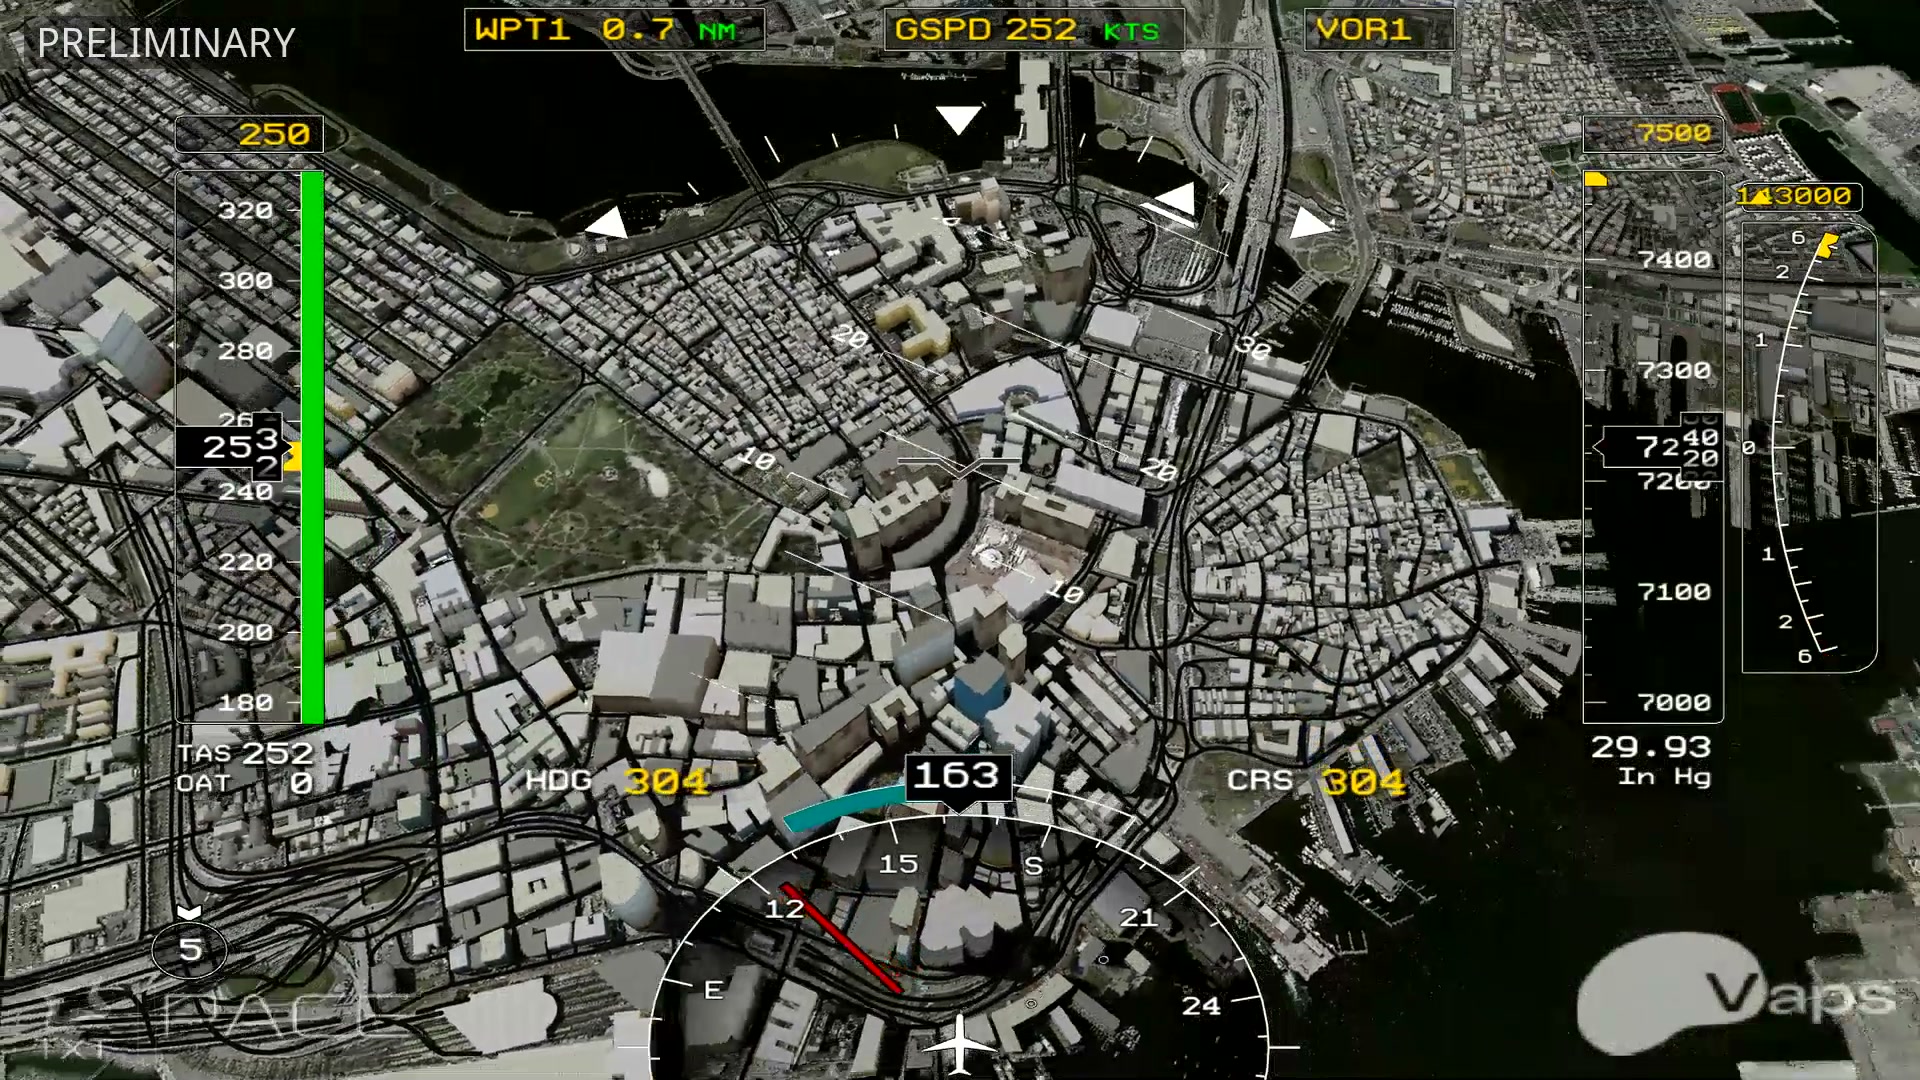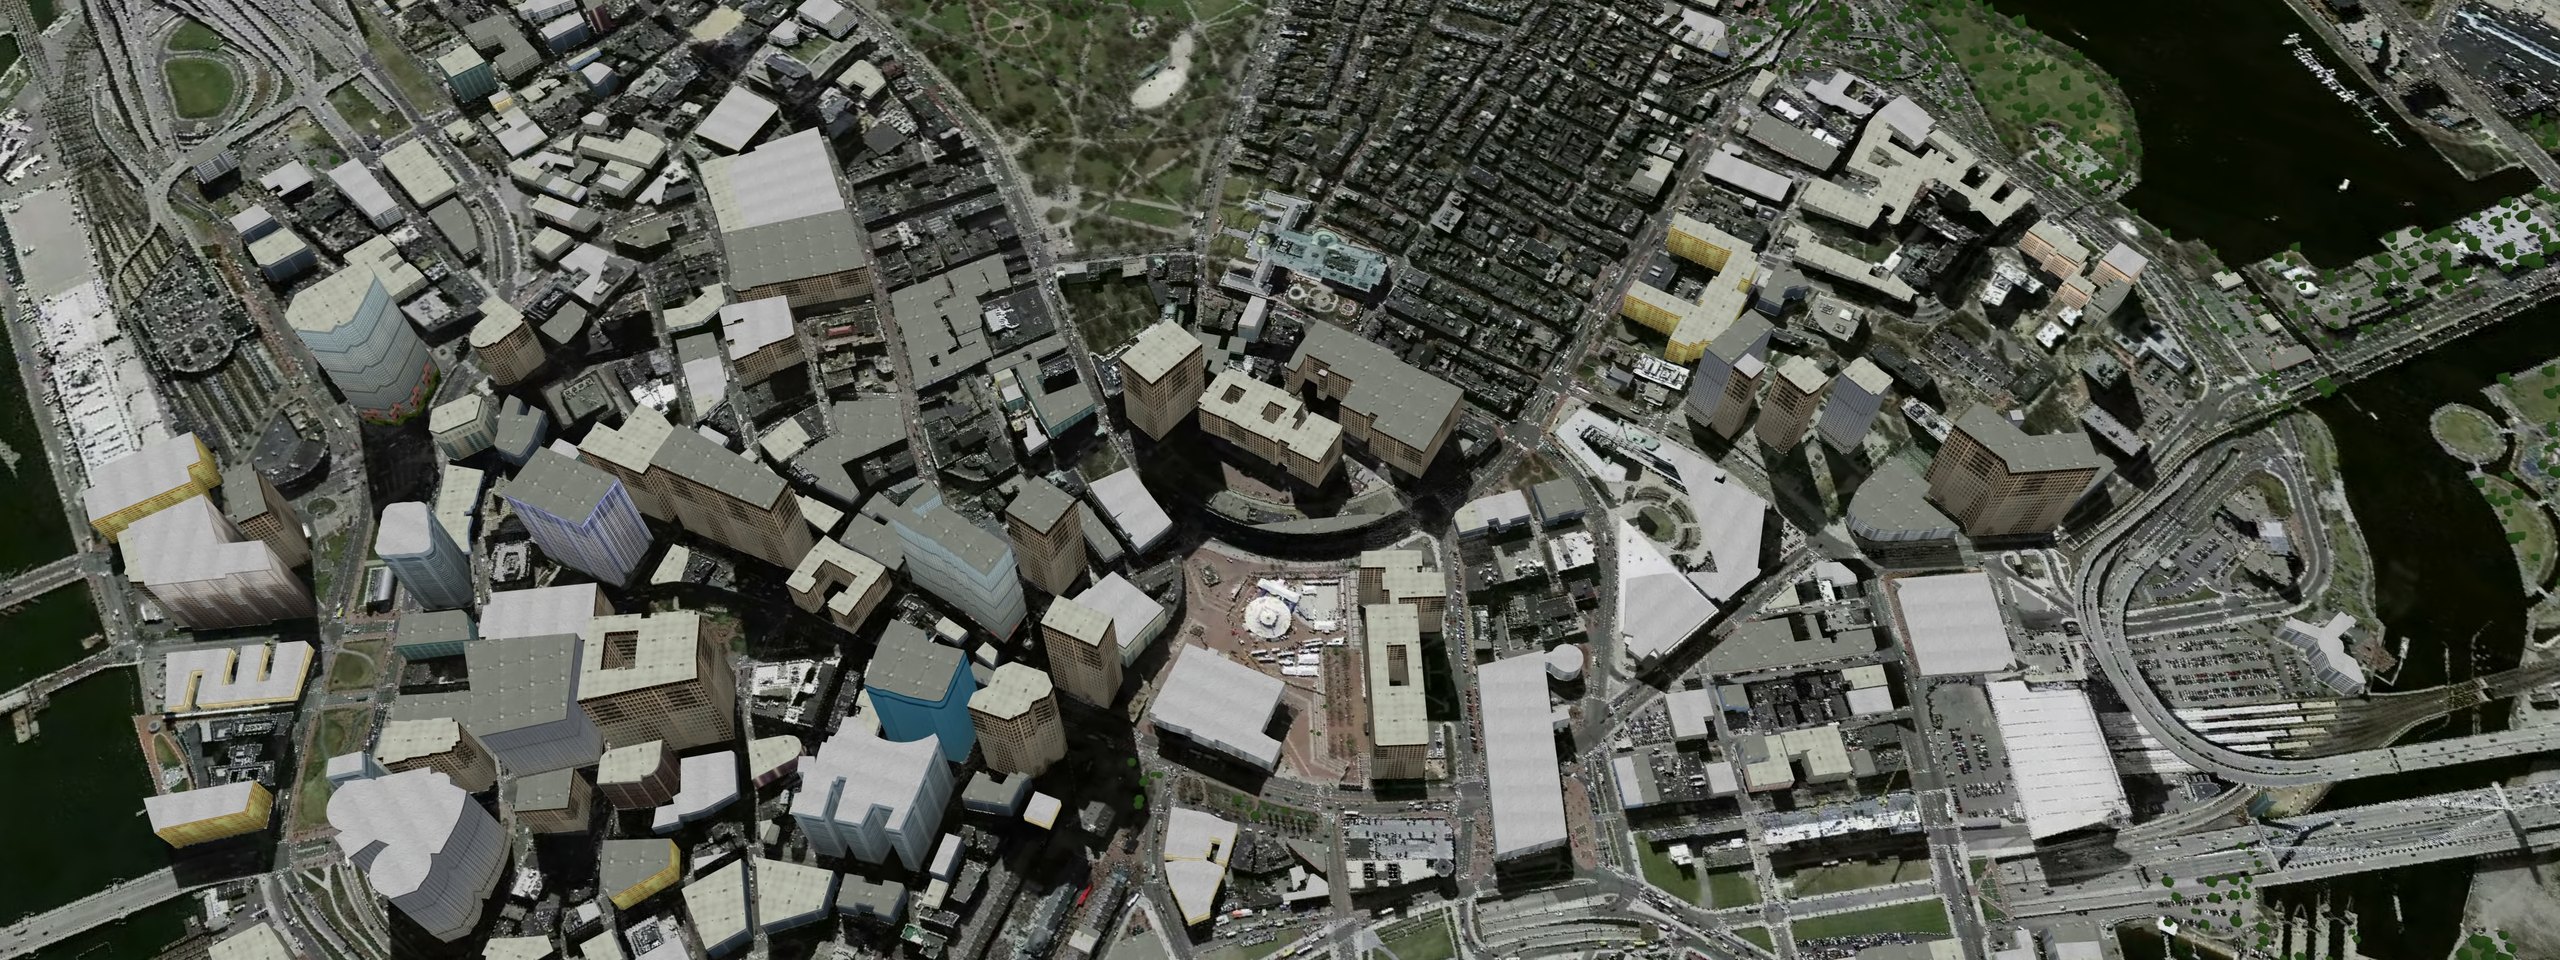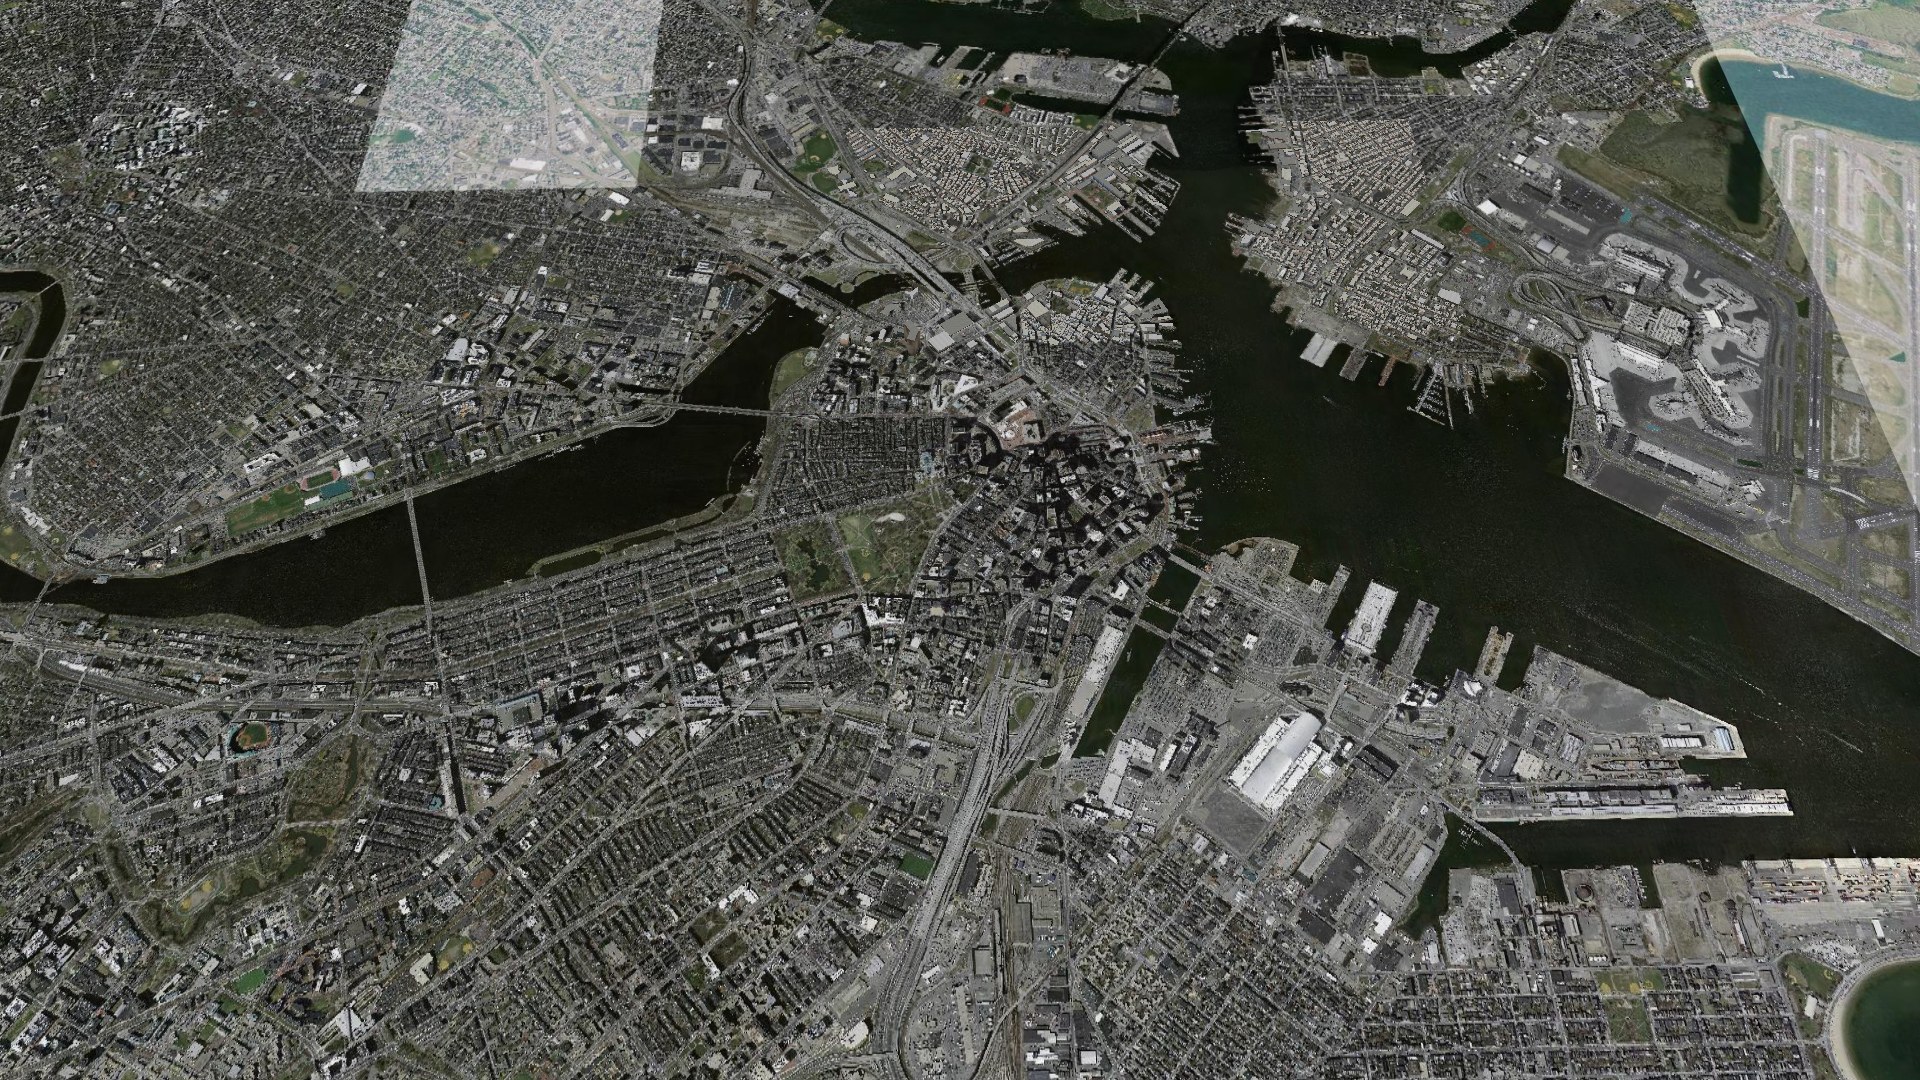
Applications already running on EVE through EagleFlight™: Pace VAPS XT, ENSCO IData, OpenSceneGraph and osgEarth. They are the building blocks of the programs EVE serves: primary flight displays, synthetic vision over real terrain and cities, and the fused views that give crews and pilots their situational awareness.
Pace VAPS XT over osgEarth
The Boston flight
EagleStream™: live video with overlays (in development)
The fused views crews depend on start with live video: a ring of vehicle cameras, an aircraft’s sensor turret, a ship’s thermal and docking cameras, a stream from another platform. EagleStream™ is the path EVE is adding that brings that video in and draws the symbology over it, under the same rules as the rest of EVE: declared buffers, no heap, and a measured, reported frame age. The standards it is being built to:
- Camera and sensor interfaces: MIPI CSI-2, GigE Vision 2.2 and 3.0 with GenICam, ARINC 818-3 (Avionics Digital Video Bus), and SDI (SMPTE ST 292-1 and ST 424); Video4Linux2 on Linux.
- Vehicle and network video: RTP (RFC 3550) and RTSP 2.0 (RFC 7826), with RTSP 1.0 for existing IP cameras; NGVA (STANAG 4754) and its video standard PLEVID (STANAG 4697).
- Video metadata: STANAG 4609 and MISB KLV (SMPTE ST 336), carried in MPEG-2 transport streams and over RTP, for overlays that follow the sensor.
- Marine and IP cameras: ONVIF IP cameras (Profiles S, T and M), IEC 61162-450 shipboard networks, and IEC 62288 for navigation information on bridge displays.
- Compressed video: H.264 and H.265 (ITU-T H.264 and H.265, carried over RTP by RFC 6184 and RFC 7798), decoded by the SoC’s hardware decoder where it has one.
- Zero-copy frames: EGLImage (EGL_KHR_image_base), EGL_EXT_image_dma_buf_import and GL_OES_EGL_image_external, with YUV formats such as NV12 converted on the GPU by shaders the EagleFledge™ Compiler prepares ahead of time; GStreamer pipelines on Linux.
- Composition and integrity: overlays drawn by EVE over the video, or video on its own hardware display plane under the symbology, with frozen-frame and frame-age monitoring through EagleWatch™.
Stills